
Section 19.1 Serial communication
Chapter 18 introduced serial communications and the two problems that must be solved in any serial link design (Figure 19.1.1):
- The receiver’s serial-to-parallel register must shift at the proper times, once per bit, and safely within each bit.
- The receiver must know when a new packet is arriving, so that the stream is properly framed into bytes.
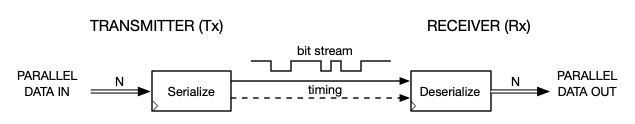
In the UART protocol for asynchronous serial communication, the synchronization is embedded in the data stream (Section 18.2). In this chapter we will see a different approach, a synchronous protocol called the Serial Peripheral Interface (SPI) bus. It solves the synchronization problem by sending a clock signal and a framing signal alongside two (transmit and receive) data lines. A state machine in the transmitter generates the timing signals, and a state machine in the receiver uses the timing signals to control the receiver’s shift register.
The SPI bus is used for package-to-package communication on a single circuit board. It is capable of full duplex (bidirectional) communication at high speeds, up to 10 million bits per second. Many of the peripheral modules, or Pmods, available for the Digilent FPGA development boards use a SPI interface.
1
store.digilentinc.com/by-communication-protocol/spi/
